Mechanical engineering · Mechatronics · Robotics

Engineering ideas
into motion.

I’m Roozbeh, a mechanical engineer and roboticist. I design mechanisms, build automated systems, and bring hardware from concept to validation.

Tempe, Arizona / Ph.D., Robotic Systems Engineering

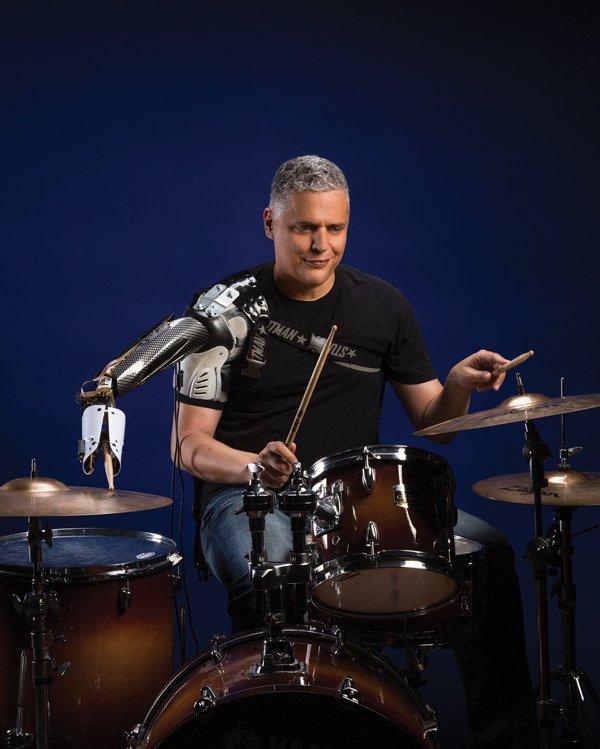
Drummer performing with a shoulder-mounted robotic arm
HUMAN AUGMENTATIONProf. Gil Weinberg giving the Third Arm a try
Precision mechanismsMotion controlHardware integrationPrototype → production

01 / Selected work

Mechanisms with a purpose.

From satellite tracking to robotic augmentation, a selection of systems I’ve helped bring to life.

This portfolio features publicly available demonstrations of my development work. Confidential company information and proprietary design details are excluded.

A progression in engineering 2014 → present

Chronological project order: Georgia Tech, Arizona State University, Calviri, then Kinematics.

03Manufacturing automation

Calviri · 2022–2024

Assay process development & automation

Robotic chip handling within the assay development workflowWatch on YouTube ↗

System design across chip fabrication, packaging, and assay equipment, reconciling interdependent requirements to enable automation throughout the workflow.

90%equipment cost reduction through a reconfigurable mask subsystem
Engineering contribution

Developed processes and hardware across fabrication, chip packaging, and assay automation, bringing requirements from manufacturing and downstream equipment into the design. Packaging served as the interface between the chips, robotic handling, and assay instruments.

Designed, manufactured, and validated an automated synthesis system. Replaced fixed glass masks with a reconfigurable photolithography mask subsystem, enabling three times higher iteration efficiency.

Collaborated on wafer layout and chip sizing to improve production yield by 30%, and engineered a pick-and-place robot for silicon chip packaging.

Process development / System design / Automation integration

View project & 6 videos ↗

04Precision mechatronics

Kinematics · 2024–present

Satellite Tracking and Motion Control

Satellite tracking and motion control in actionWatch on YouTube ↗

Precision mechanisms and control systems for satellite tracking, combining mechanical design, sensing, and trajectory generation.

0.03°actuator backlash, reduced from 0.2°
Engineering contribution

Designed a two-degree-of-freedom XY positioner with planetary and worm gear trains, applying GD&T and tolerance analysis for sub-degree alignment.

Integrated BLDC drives and absolute rotary encoders, simulated robotic systems in ROS 2 and Gazebo, and developed satellite trajectory generation and tracking algorithms in Python.

Mechanical design / Motion control / ROS 2 / Python

View project & 2 videos ↗

01Human augmentation

Georgia Tech · 2014–2016

A wearable robotic arm

Earlier robot version. Video by Georgia Tech.Watch on YouTube ↗

Wearable augmentation for musicians, alongside EMG-controlled prosthetic drumming for an amputee musician.

Engineering contribution

Designed SOLIDWORKS models and prototypes, implemented input shaping control, and interfaced Kinect, EMG, and hand-motion sensors to control the arm.

Read the input shaping paper (PDF) ↗

View project & 8 videos ↗

02Soft robotics & sensing

Arizona State University · 2017–2021

Artificial muscles & soft robotics

Untethered miniature hydrogel robotWatch on YouTube ↗

Stimuli-responsive materials and wearable devices at the intersection of mechanics, sensing, and human movement.

20×increase in hydrogel actuator response rate
Engineering contribution

Formulated and validated a hydrogel actuator using thermal and structural analysis, with results published in Advanced Materials.

Developed a wearable MEMS pressure sensor array with flexible PCBs and experimental fixtures, and a joint-support device using IMUs and microcontrollers.

Multiphysics analysis / MEMS / Flexible electronics / Prototyping

View project & 6 videos ↗

02 / Approach

Mechanical foundations.
Systems thinking.

My work connects mechanical design, electronics, and control to solve problems in the physical world.

With a Ph.D. in Robotic Systems Engineering and experience across healthcare robotics, semiconductor equipment, and satellite systems, I work across the full hardware lifecycle: requirements, design, prototyping, integration, testing, and manufacturing release.

Design & simulate

SOLIDWORKS · Creo · GD&T
ANSYS · COMSOL · MATLAB

Build & integrate

Precision mechanisms · Test fixtures
BLDC motors · Encoders · PCBs

Control & automate

Python · C/C++ · ROS 2
Gazebo · Embedded systems

Validate & manufacture

Verification & validation · DFMA
Supplier collaboration · Prototyping

03 / Experience

Research to real-world hardware.

Full resume ↗

2024–present

Senior Mechatronics Engineer

Kinematics LLC · Scottsdale, AZ

Satellite positioning & automation

2022–2024

Product Development Engineer

Calviri Inc. · Phoenix, AZ

Assay process development & automation

2017–2021

Research Assistant

Arizona State University · Tempe, AZ

Soft actuators & wearable sensing

2014–2016

Research Assistant

Georgia Institute of Technology · Atlanta, GA

Wearable robotics & prosthetics

04 / Get in touch

Let’s build something
that moves.

For engineering opportunities, research, or a conversation about robotics.

rkhodambashi@gmail.com